HEXAPOD REAL CUTE ANIMATION STUDY
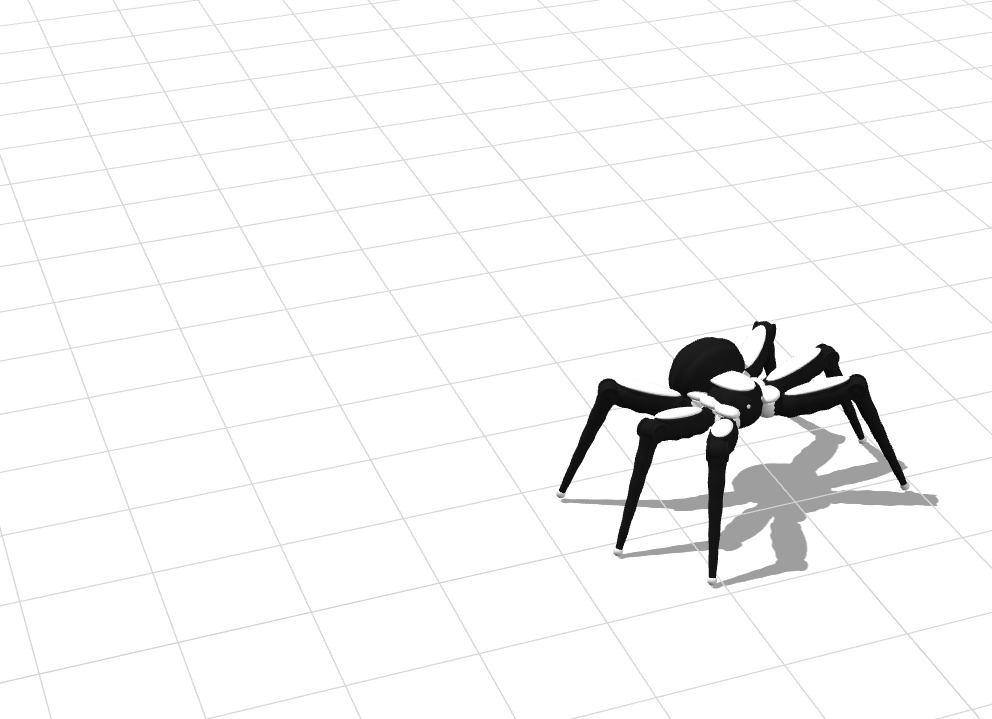
Web-based prototype for a walking six-legged creature with procedural leg animation. The creature is built from simple 3D shapes and moves with an inverse-kinematics leg system on a flat ground plane. A single slider blends the character between a cute and a spider-like appearance, changing speed, stride, body height, gait and other motion parameters. The gait can be switched between a tripod pattern and a wave pattern, and the creature can duck, tuck its legs into a protect pose, or rear up. Three smaller companion creatures can be added, each following the main figure with one of several behaviour modes such as shy, bold, wild or ignorant. An experimental sound layer turns footfalls into plucked tones and adds a continuous drone that follows a chord progression, with movement values mapped to sound parameters. The prototype is made for design exploration of creature motion and for experimenting with movement-driven sound.
- Version: r128
- Character slider blends between cute and spider-like proportions and motion
- Six legs animated with inverse kinematics and tripod or wave gait
- Duck, protect and rear-up poses with keyboard and panel control
- Three optional companion creatures with shy, bold, wild and ignorant behaviour modes
- Experimental audio with footstep plucks, drone and chord progressions
- Movement values can be assigned to sound parameters
- Tech: Three.js r128, WebGL, Web Audio API
- Requires: WebGL-capable browser, internet connection for Three.js from a CDN, audio output for sound
LIVE DEMO : https://code.turboflip.de/run/d5efadba0eca72df/